


AI learned to describe the world. It never learned to see it.
We are building the perception layer for machines that have to act.

THE LLM WALL
Scale stopped working
The industry's answer to every limit on machine cognition has been more data and more compute. That worked while the product was language, because language is where the training data lives. It stops working the moment the output has to be accountable to our physical reality.
A model trained on records of the world becomes fluent in how the world is described and never makes contact with how the world is.
The industry has bet the house on the leap into physical machines. Drones, robotics, autonomous vehicles, industrial sensing, all of them need a machine that can act on what is actually in front of it.
The prevailing architecture was never built to stay coupled to reality, and no amount of data centers can compensate for that.

THE UNLOCK
Enactive AI

Biological intelligence never had this problem, because it never worked from descriptions. Cognition in nature emerges from continuous engagement between an organism and its environment. Perception and action are bound together, and reality corrects every prediction and conclusion in real time. Francisco Varela, Evan Thompson and Eleanor Rosch called this enaction: intelligence is not computation performed on representations, it is action grounded in the physical world.
Enactive AI describes a system that carries a model of reality, tests it against the overwhelming incoming sensory signal, and updates on the difference. It stays accurate through accountability to the real world, like the rest of us.
PERCEPTION, NOT CAPTURE
What this looks like as engineering
An apple falls, but how do you catch it if you can never perceive the present.
Neural signal takes time to arrive, so by the moment an image reaches you the world has already moved on.
What you experience is a running forecast, weighted by everything you have ever watched move and corrected until your fingers close around the apple. Perception is not a passive snapshot. It is an active prediction, disciplined by reality.
Machine vision, like a camera, treats each frame as evidence rather than as a test of anything, so an error introduced at the sensor travels intact to the output and arrives with unearned confidence. Biology inverts this. Predictions descend, incoming signal tests them, and only the error travels back up.

STEP ONE
Perception built on vision

We started with vision because it is the primary way in which intelligence senses and couples to reality.
MYSTIC reads the scene, works out what is degrading it, and reverses that specific degradation. It is not filling in what the fog might be hiding. It measures the fog, and known physics undoes it, which means detail that was not in the world cannot appear in the image. At every step AIALF is predicting and validating those predictions through inference. When the incoming signal cannot be reconciled with physics, the system flags it rather than smoothing it over.
A machine cannot decide what to do about something it cannot see. Improve the way it senses and the picture gets better. Give it the power to move and it improves the picture and the operator's ability to respond.
We started with vision because it is the primary way in which intelligence perceives and couples to reality.
MYSTIC reads the scene, works out what is degrading it, and reverses that specific degradation. It is not filling in what the fog might be hiding. It measures the fog, and known physics undoes it, which means detail that was not in the world cannot appear in the image. At every step AIALF is predicting and validating those predictions through inference. When the incoming signal cannot be reconciled with physics, the system flags it rather than smoothing it over.
A machine cannot decide what to do about something it cannot see. Improve the way it senses and the picture gets better. Give it the architecture of perception and it improves the the operator's ability to see clearly and respond quickly.
ONE SCENE
Every sensor, one world
Sight alone is not perception. An organism does not maintain a separate world for each sense. It maintains one world that every sense contributes to.
Fusion is next for MYSTIC. Electro-optical, infrared, radar, acoustic and inertial inputs resolved into a single continuous estimate of what is actually there, where a track acquired on one sensor stays the same track on the next, and a signal too weak to trust alone becomes decisive in combination.
the sensor
Hardware built for a mind that predicts

Today's sensors were designed for human eyes and human displays. They optimize for a picture, and they discard most of what they measured in order to produce one. A machine that perceives by prediction wants the opposite: every raw physical measurement we can capture, at every the moment, in real time.
MYSTIC runs on the sensors you have, while we develop the sensing hardware you need.
STEP TWO
Perception is only half of it
An organism perceives in order to act, and acts in order to perceive better. Movement changes the view, the new view corrects the model, and the corrected model directs the next movement. That is when enaction becomes possible.
This is why perception had to come first. Autonomy has been bottlenecked on it the entire time. A machine cannot decide what to do about a thing it cannot resolve, and understand. Reacting to language and still frames is a dead end for perception, Fog. Night. Dust. Loss of GPS. The moments an operator most needs the machine to think for itself are the moments it goes blind.
SÉANCE
Enactive Autonomy
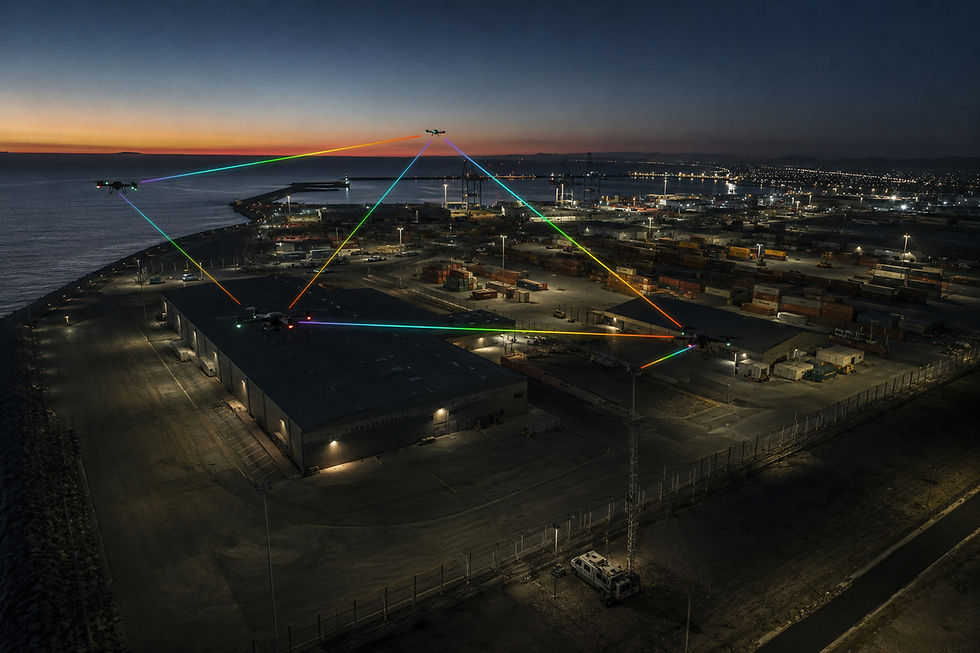
SÉANCE is MYSTIC's autonomy layer. Drones coordinate coverage across a site, adapt as conditions change, and hold the picture without an operator flying them, relaying to a base station over a secure link.
One operator. Continuous coverage. Available for qualified defense and security deployments.
WHAT COMES NEXT
The intelligence of every sensor
MYSTIC begins as sight for cameras. It becomes the perception layer for anything that has to act in the physical world. Drones, ground robots, maritime platforms, fixed infrastructure, entire sensor networks holding one shared understanding of a place, in real time, on site, under the operator's hand.
We are building the AI that makes contact. Every feed answering to one understanding of what is real, an operator's reach extended across all of it at once.